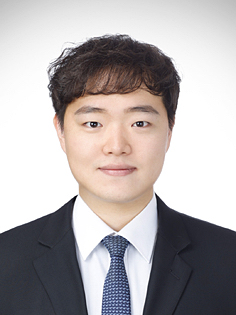
Bongsub Song

Logo

Research Portfolio of Bongsub Song, Ph.D. Researcher at ETRI specializing in Robotics, Reinforcement Learning and Field Robotics.

View My GitHub Profile

Projects


Ongoing

Image coming soon

ETRI · 2025 – Present

Planning Study on Cost-Effective Precision Grippers Based on Tactile Sensors

Defining design directions and application scenarios for cost-effective tactile-based precision grippers.

Image coming soon

MSIT · 2025 – Present

Development of Reinforced Embodied Intelligence through Active Interaction in Real-World

Reinforcement learning and sim-to-real transfer for embodied AI in physical robot systems.


Completed

Image coming soon

MOTIE · 2022 – 2025

Safety Robot for Wireless Operation, Detection, and Response in Narrow Spaces

Wireless-operated safety robot for confined-space detection and emergency response missions.

Image coming soon

MOTIE · 2022 – 2024

Gripper Systems for High-Mix Production Processes

Adaptive grasping of objects with varied shapes, weights, and stiffness in manufacturing lines.

Image coming soon

KAERI · 2022 – 2023

Control Algorithms for UGV Sampling Manipulators

Performance evaluation and functional testing of sampling manipulators on unmanned ground vehicles.

→ View Details
Image coming soon

Hyundai Motor Group · 2022 – 2023

Freedom of Movement: A Drivetrain Study for Future Autonomous Mobility

Drivetrain concept and vehicle dynamics study for next-generation autonomous mobility platforms.

→ View Details
Image coming soon

MOTIE · 2020 – 2022

Off-The-Ground (OTG) Mobility Technology for New Personal Mobility

Dynamics modeling and control design for floating personal mobility platforms.

→ View Details
Image coming soon

MOTIE · 2019 – 2021

Narrow Space Navigation Robot for Detection and Rescue

Autonomous navigation robot for victim detection and rescue in post-disaster confined spaces.

→ View Details
Image coming soon

MOTIE · 2018 – 2019

Shape-Adaptive Electro-Adhesive Gripper for Grasping Arbitrary Shaped Objects

Electro-adhesion based variable-friction gripper for stable grasping of arbitrary-shaped objects.

→ View Details

Last updated: April 2026